Find below graphics, videos and other outreach materials.

The EMERGE Project - Video Abstract (German Subtitles)
How do robots in a collective know what the group as a whole is doing? How can connected devices make sense of the world around them with so many interconnections? How can a robotic arm composed of many independent parts understand how its body is behaving as it reaches for an object?

The EMERGE Project - Video Abstract (Italian Subtitles)
How do robots in a collective know what the group as a whole is doing? How can connected devices make sense of the world around them with so many interconnections? How can a robotic arm composed of many independent parts understand how its body is behaving as it reaches for an object?

The EMERGE Project - Video Abstract (French Subtitles)
How do robots in a collective know what the group as a whole is doing? How can connected devices make sense of the world around them with so many interconnections? How can a robotic arm composed of many independent parts understand how its body is behaving as it reaches for an object?

The EMERGE Project - Video Abstract (English Subtitles)
How do robots in a collective know what the group as a whole is doing? How can connected devices make sense of the world around them with so many interconnections? How can a robotic arm composed of many independent parts understand how its body is behaving as it reaches for an object?

The EMERGE Project - Video Abstract (Dutch Subtitles)
How do robots in a collective know what the group as a whole is doing? How can connected devices make sense of the world around them with so many interconnections? How can a robotic arm composed of many independent parts understand how its body is behaving as it reaches for an object?
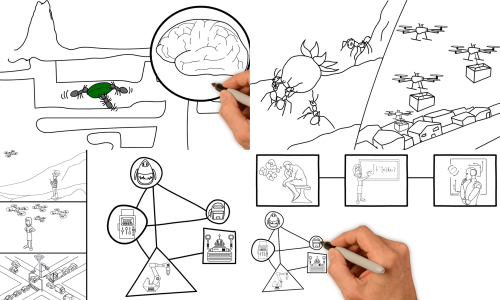
The EMERGE Project - Video Abstract
How do robots in a collective know what the group as a whole is doing? How can connected devices make sense of the world around them with so many interconnections? How can a robotic arm composed of many independent parts understand how its body is behaving as it reaches for an object?